Started Sep 2026 · Independent project
- Goal
- Design and tune the motion control for a printer whose nozzle tilts, before any hardware exists.
- What I did
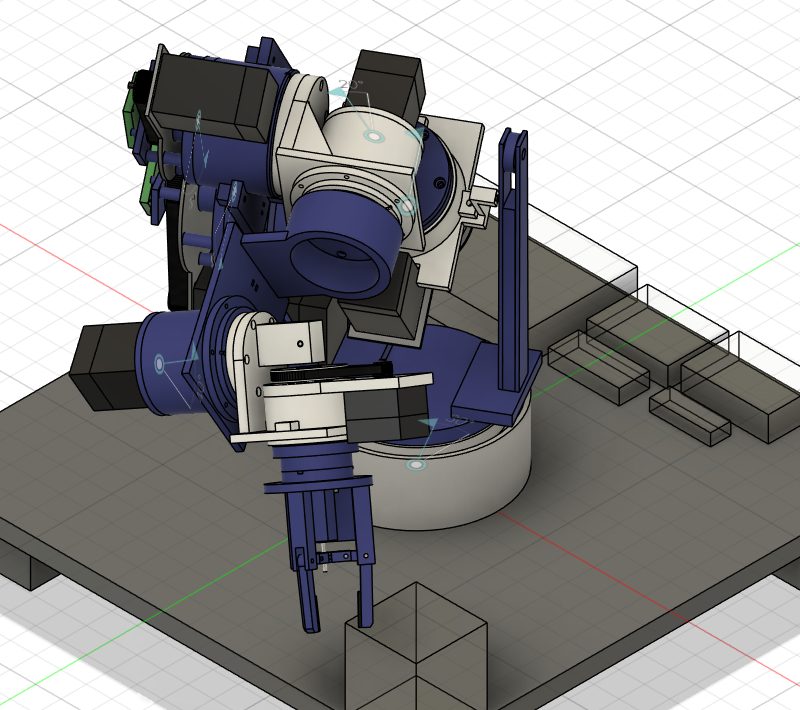
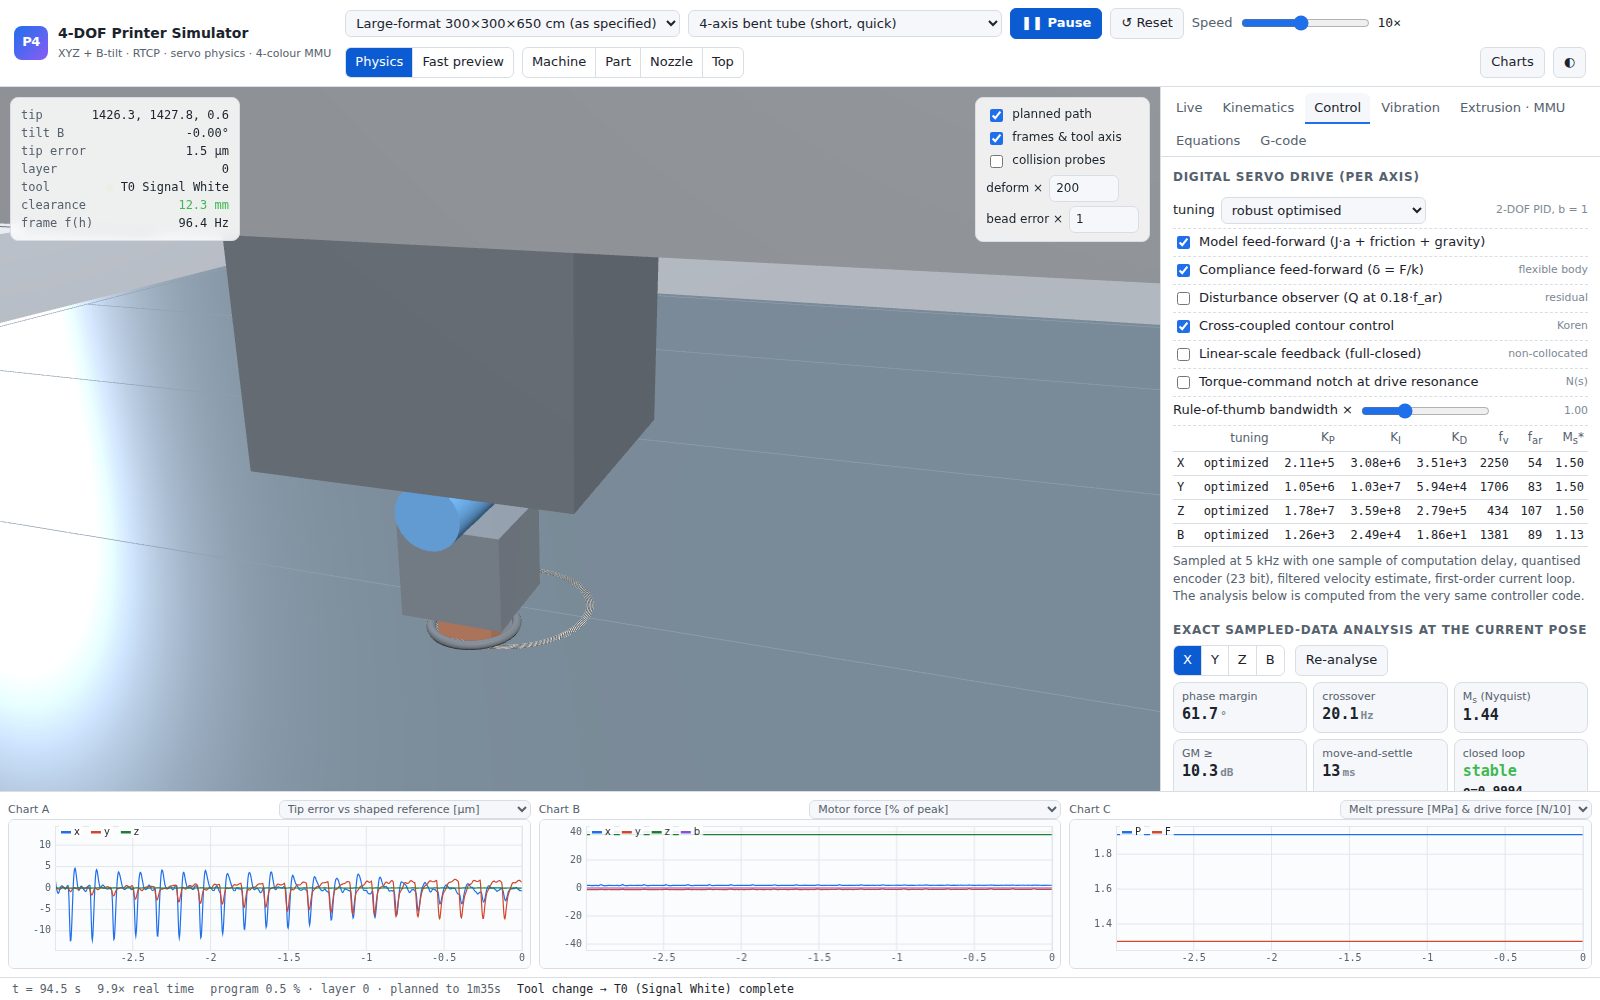
- A browser-based simulator of a Cartesian 3D printer with a fourth, rotary axis that tilts the nozzle, so steep overhangs print without supports. It has closed-form kinematics, a look-ahead motion planner, flexible-structure models, and a 5 kHz digital PID servo per axis with vibration compensation and flow calibration. The engine runs in Node with no browser, and has 31 tests.
- Result
- A 5 kHz digital servo with vibration compensation, covered by 31 tests.